


PROJECT NOTES / INTERACTIVE 3D / ROBOTICS
a mission in motion: robotics in the browser
A browser-based 3D factory mission exploring how interactive storytelling, synchronized camera views, and practical interfaces can make autonomous robotics easier to understand.
By Chino Pisces · October 17, 2026 · 5 min read
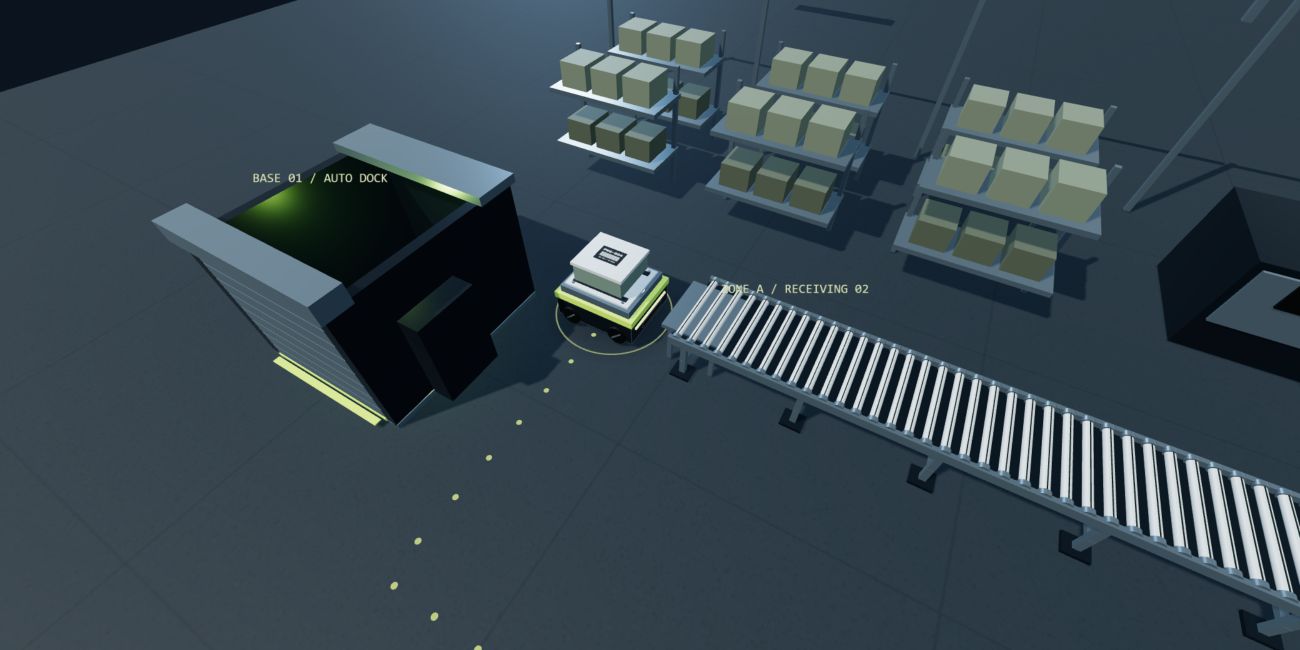
What does an autonomous robot actually do between receiving an instruction and completing a delivery? That question became the starting point for AMR — A Mission in Motion, an interactive 3D factory experience I built to make a robotics workflow visible from beginning to end.
The visitor follows one autonomous mobile robot through a complete assignment: receive an order, leave its dock, collect a package, travel across the factory, deliver the load, report completion, and return to charge. It turns a sequence of system behaviors into a story people can follow.
Explore AMR — A Mission in Motion
One mission, three ways to see it
The experience opens through a security camera. This gives the scene a useful starting point: you are observing a working environment, with a robot moving through it. As the mission progresses, the feed switches between fixed cameras to keep the robot in view.
You can change viewpoints at any time. Robot POV puts you at the unit’s navigation level, where its destination, speed, safety state, and current operation become the focus. The top-down view makes the route easier to read in relation to conveyors, stations, and other traffic. The security view places that same activity back inside the larger factory.
All three views share one mission clock. Switching cameras changes the perspective while preserving the operation’s progress. Press Begin and the robot’s movement, interface updates, and page narrative advance together. You can pause or move through the timeline to revisit a particular moment.
The useful details happen between the big actions
A robot moving from A to B is easy to summarize. The details around that movement explain much more about how a system is intended to work.
Before departure, the robot receives and acknowledges its order. Its docking door opens and releases the unit into the aisle. At receiving, the robot aligns with a supported conveyor and accepts the package without the box rotating during transfer. The payload stays with the robot as it travels to a delivery station in a separate production hall.
The floor is shared. Another logistics robot crosses the route, a repair unit follows its own service loop, and a pedestrian walks through the main unit’s path. The delivery robot pauses at the crossing events, reports the hold, and resumes after clearance. After unloading and acknowledging delivery, a low-battery warning prompts its return to the charging base.
Those small transitions create the sense of a complete operation. The destination matters, but so do the acknowledgments, the waiting, the handoff, and the return.
An interface that explains what is happening
The interface is part of the demonstration. Planned route points stay anchored to the factory floor, and the map uses the same positions as the 3D scene. Its markers show the delivery robot, surrounding units, and pedestrian so the viewer can connect a status message with an event in the environment.
A running command list records requests, responses, and acknowledgments. Text types into the panels as information arrives. Progress messages accompany loading and unloading, and warnings appear at the relevant points in the mission. The intention is a practical monitoring interface: information should help the viewer understand the next action.
Lighting, concrete and metal materials, contact shadows, and small robot details give the environment more depth. The visual work supports the operation by making objects, movement, and relationships easier to read.
Why this format can be useful
Product demonstrations. A robotics company could use a browser experience like this to walk visitors through a specific use case. A buyer can see the pickup, shared aisle, delivery, and charging cycle in context, then change viewpoints to inspect the parts that interest them.
Sales conversations and exhibitions. A repeatable mission gives a presenter a sequence to discuss. They can pause at a loading step, a crossing event, or a status acknowledgment and explain the intended behavior. The browser format also makes the demonstration accessible through a link.
Design reviews. Engineers, interface designers, and marketing teams can use a shared visual sequence to discuss what needs to be communicated. Does the visitor understand why the robot stopped? Is the destination clear? Does the interface acknowledge a successful handoff? The prototype makes those questions concrete.
Introductory learning. A guided mission could help newcomers become familiar with workflow stages and interface terminology. With additional development and subject-matter review, the approach could support more detailed training material.
Built to explain a system
The factory is rendered in the browser using Three.js and WebGL. A shared timeline coordinates robot motion, camera selection, interface messages, and the scrolling narrative. The mission uses scripted behavior and simulated status data; it is a communication prototype rather than a connection to a production robot.
That distinction keeps the project’s purpose clear. It demonstrates how interaction, animation, and interface design can make an unfamiliar technical process easier to understand. A production deployment would need its own engineering validation and content matched to the actual equipment.
For me, the most interesting part of the project is the relationship between the scene and the explanation. Seeing a robot pause is one piece of information. Seeing the pedestrian cross, reading the protective-stop message, and watching the route resume gives that pause meaning.
Follow the mission in the interactive experience.
BEGIN THE MISSION ↗